Plan
Define environment, coverage, control, safety, and required outputs.
Robotics & Autonomous Systems
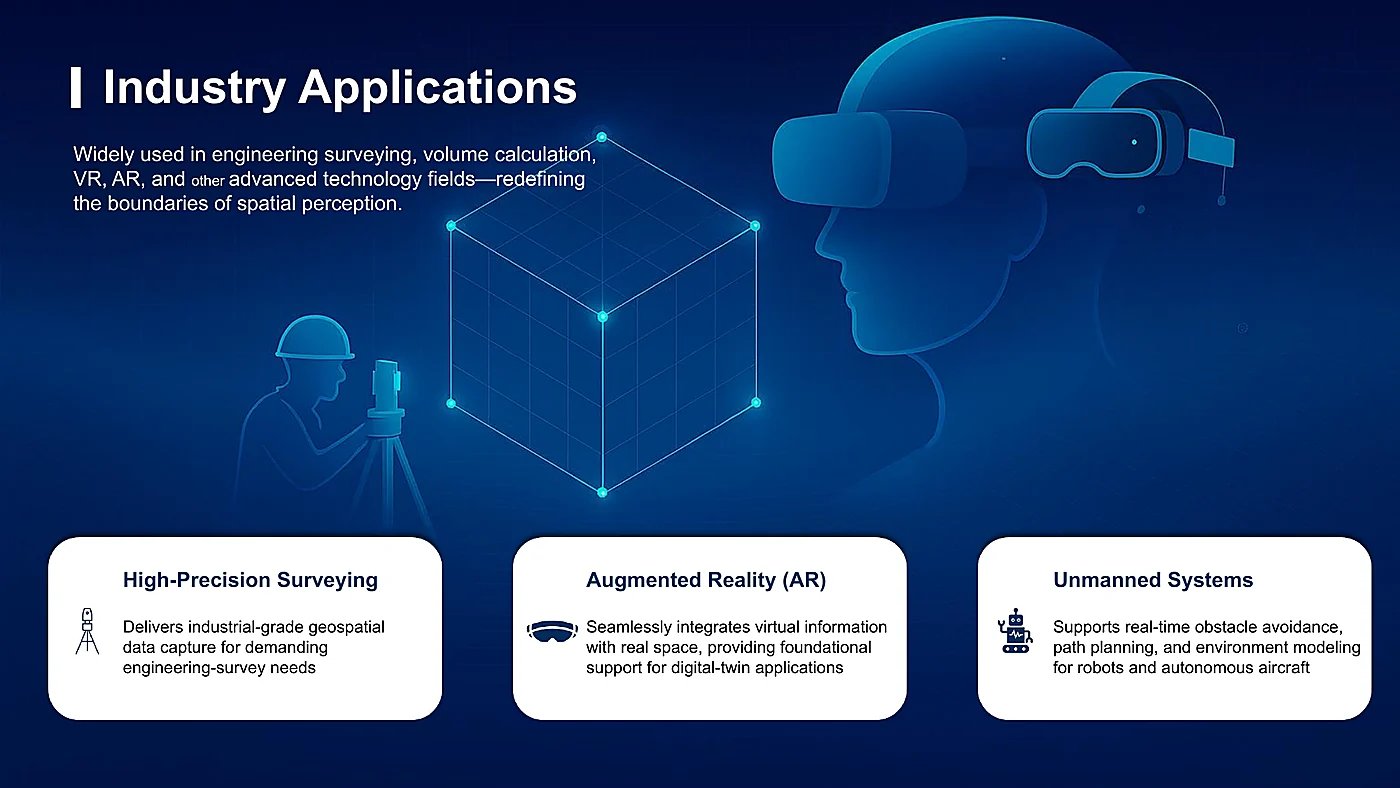
ModeXion handheld scanners provide partially open data packages and spatial outputs that can support research, mapping, and custom development workflows.
The challenge
Traditional workflows can be slow to repeat, difficult to review remotely, and inconsistent across projects. A spatial capture plan connects fieldwork to measurable deliverables.
Recommended workflow
Define environment, coverage, control, safety, and required outputs.
Collect spatial and visual data using the appropriate ModeXion system.
Generate point clouds, models, imagery, and measurements.
Provide the agreed files, records, and reports for professional review.
Reflectivity, lighting, motion, weather, obstructions, and access influence capture quality.
Separate repeatability, relative accuracy, and absolute accuracy.
Validate supported formats and downstream software before deployment.
Use spatial outputs to support—not replace—qualified decisions.